Independent projects
Shipped apps and open-source work.
VoxaVerse: 4D volumetric video on Apple silicon
An end-to-end pipeline on Apple hardware: iPhones capture, a Mac reconstructs, and any browser plays the scene back.
- Beacon is on the App Store. It uses a PTP-style clock exchange with Kalman drift filtering and a rate-nulling shutter-phase loop, reaching 84 µs median cross-phone frame pairing and 0.389 px ChArUco calibration.
- 4D Gaussian splatting engine written in C++/Metal: 32.97 dB PSNR on the six-scene Neural 3D Video benchmark (published state of the art is 33.57 dB), with 151 FPS mean GPU playback on an M3 Pro.
- 3DGS trainer: reached 26.22 dB on Mip-NeRF 360 garden in 458 s, above msplat's published 25.68 dB.
- Interoperability: glTF exports pass the Khronos validator, USDZ passes Apple's usdchecker, and the vvSpec capture format is open.
- C++
- Metal
- Swift
- Rust
- WebGPU


WinPlay: native AirPlay 2 sender for Windows
The whole AirPlay 2 sender stack, written from scratch in .NET 8: mDNS, HomeKit pairing, RTSP/RAOP, a PTP grandmaster clock, FairPlay, ALAC and H.264 mirroring. About 850 downloads.
- C#
- .NET 8
- Direct3D 11
Axhara: encrypted phone-to-USB input device
On-device speech recognition streams over end-to-end-encrypted Bluetooth LE to an ESP32 dongle that enumerates as a USB keyboard.
- Pairing handshake modelled in Tamarin and ProVerif
- Physical-button pairing gate enforced by the type system
- 0.0% word error rate on a 60-word dictation test
- Rust
- Embassy
- ESP32
- Swift
- Kotlin
Graduate projects
Case Western Reserve University, 2023–2025.
Pipeline parallelism for LLMs
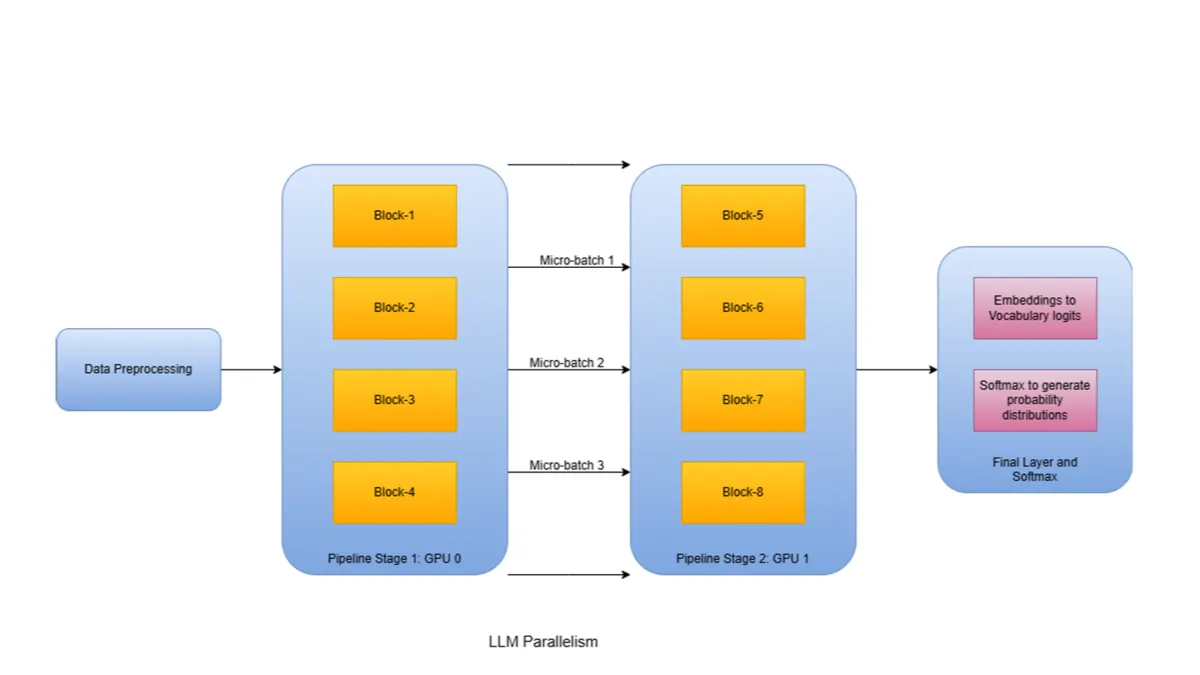
GPipe-style pipeline parallelism for GPT-style transformers on two RTX 2080 Ti GPUs, using PyTorch's pipeline-parallel APIs. Training throughput rose 42%, and per-GPU memory fell from 90% to 65%.
Panoptic 3D point-cloud segmentation
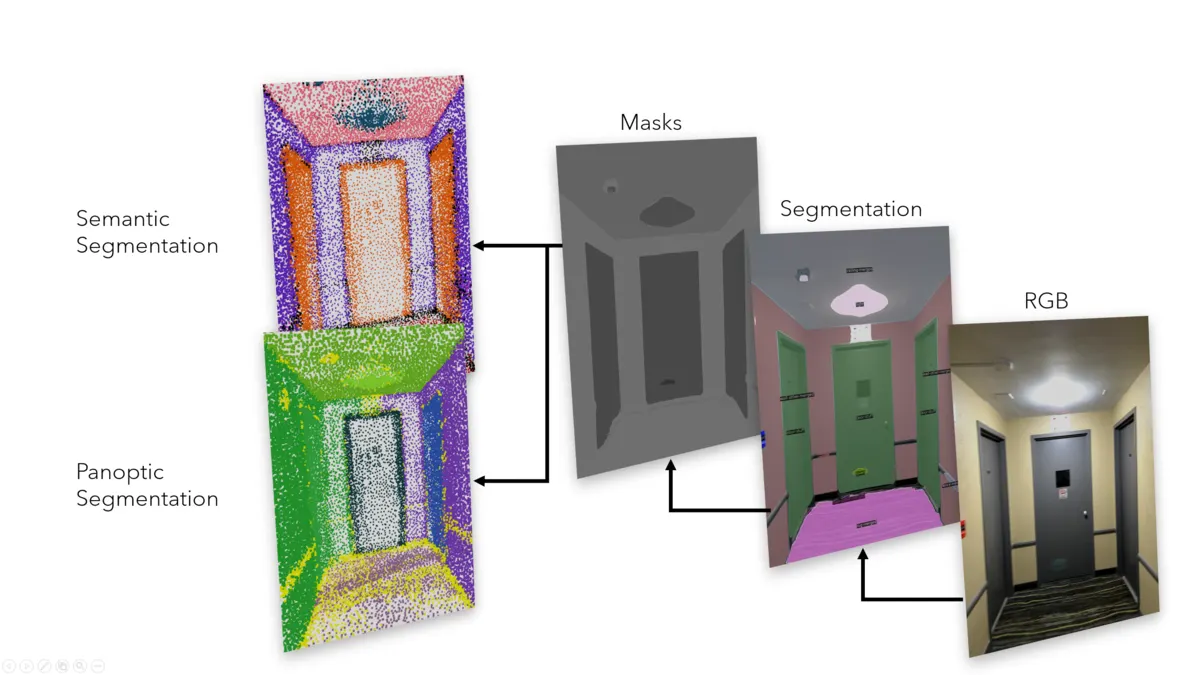
Captured iPhone 13 Pro LiDAR scans with RTAB-Map, then fused OneFormer masks (133 categories) into 3D by multi-view back-projection and voting. Team of 3.
Vehicle RoadSense ADAS
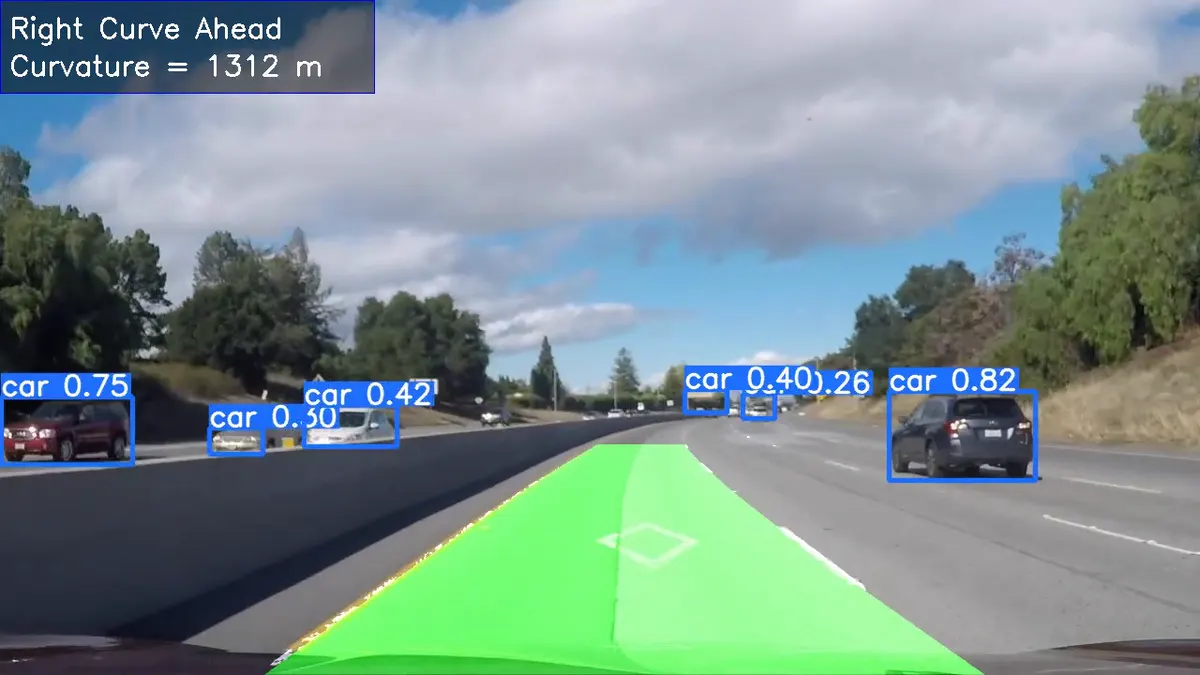
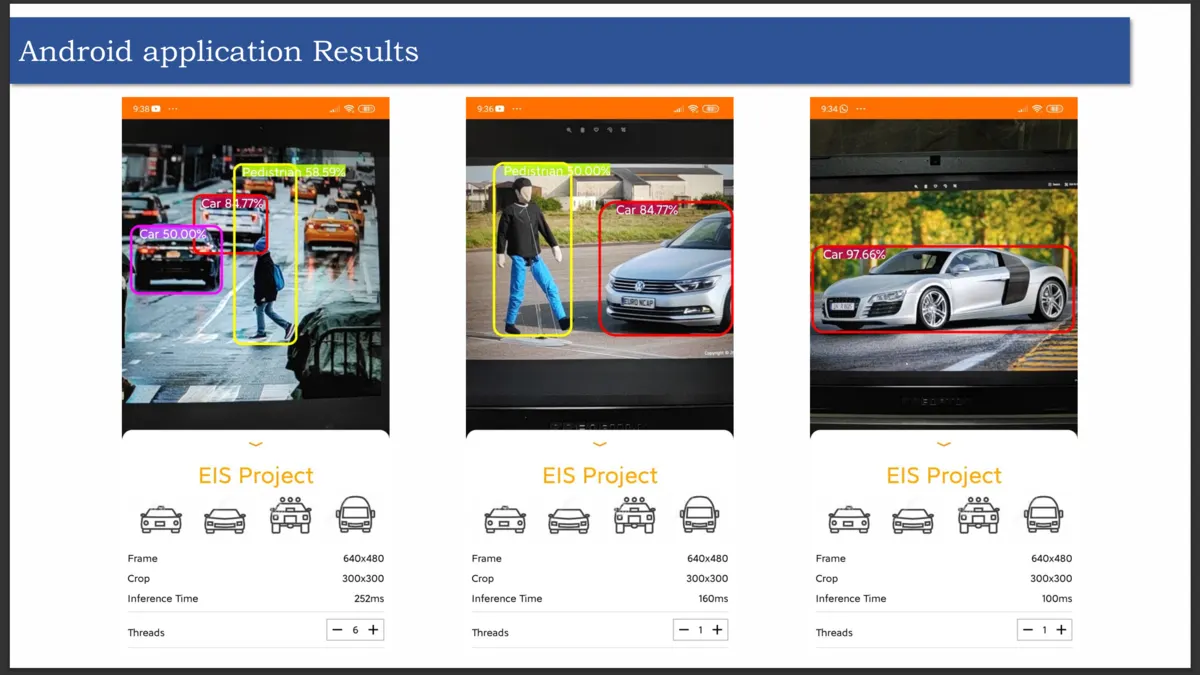
YOLOv8 detection combined with classical lane finding (calibration, bird's-eye warp, sliding windows, polynomial fit), running at 30+ FPS. Team of 2.
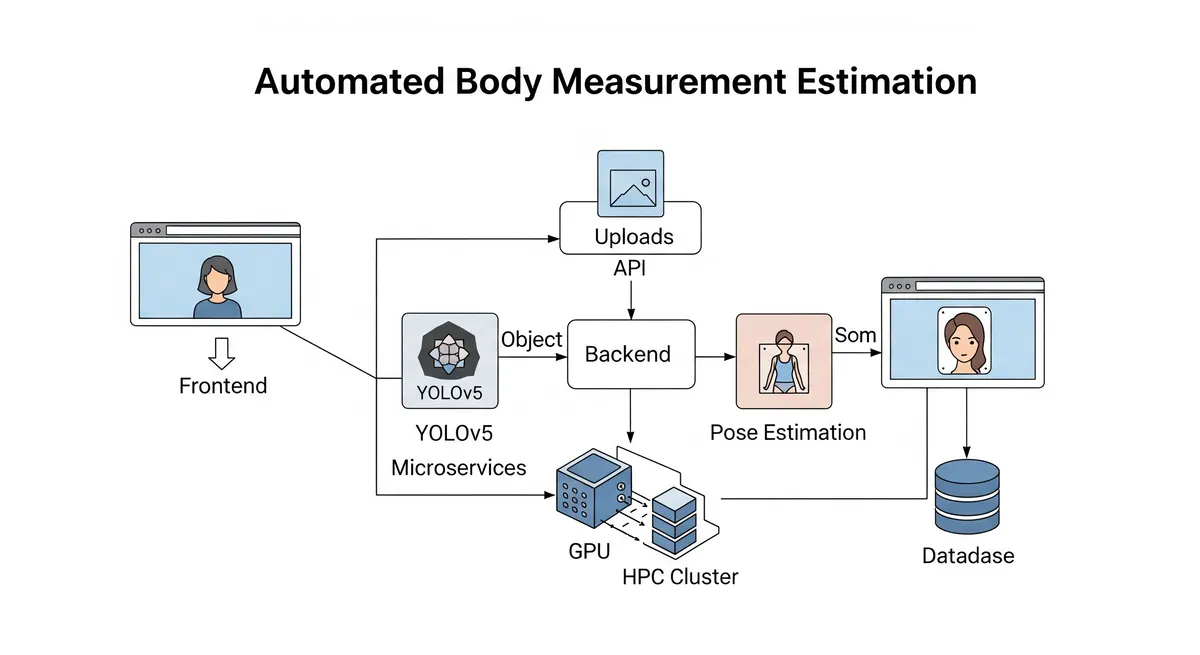
Automated body measurement
YOLOv5 landmarks refined with OpenPose, GPU-accelerated on an HPC cluster. Team of 7.
Undergraduate projects
KLE Technological University, 2019–2021.
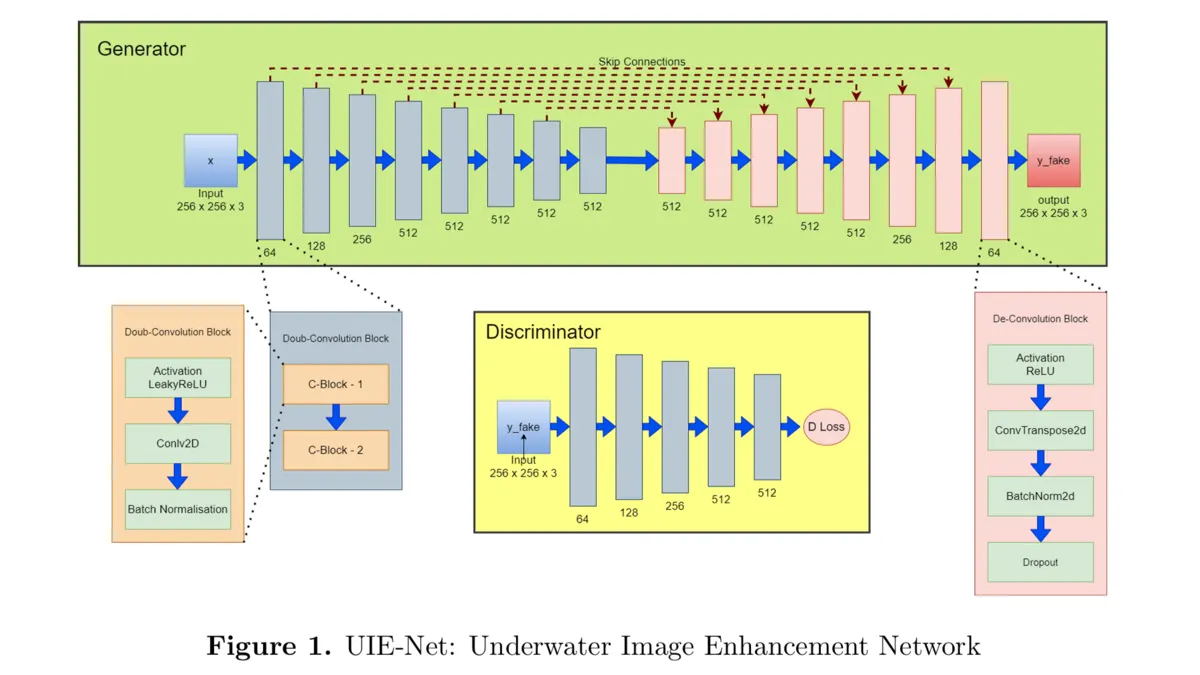
UIE-Net: underwater image enhancement
A GAN for autonomous underwater vehicles that improved visibility by 60–75%. Accepted at GC-RDCT 2021.
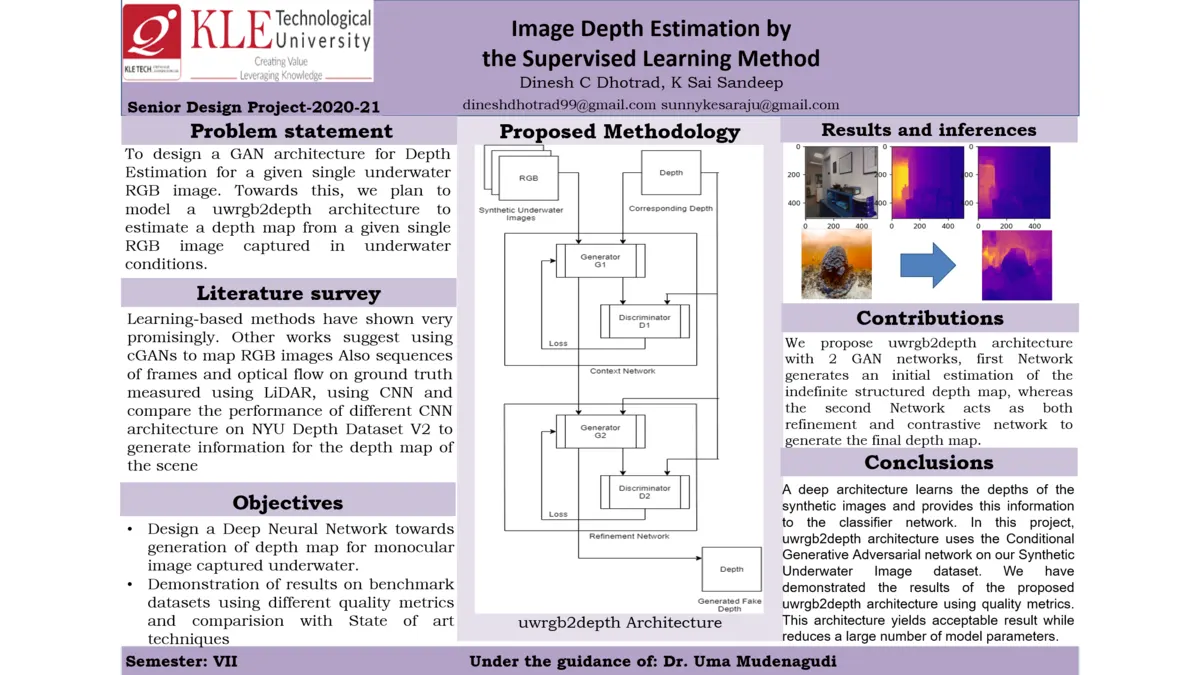
Underwater single-image depth estimation
A dual-GAN model trained on synthetic Jerlov-water renderings of NYU Depth V2.
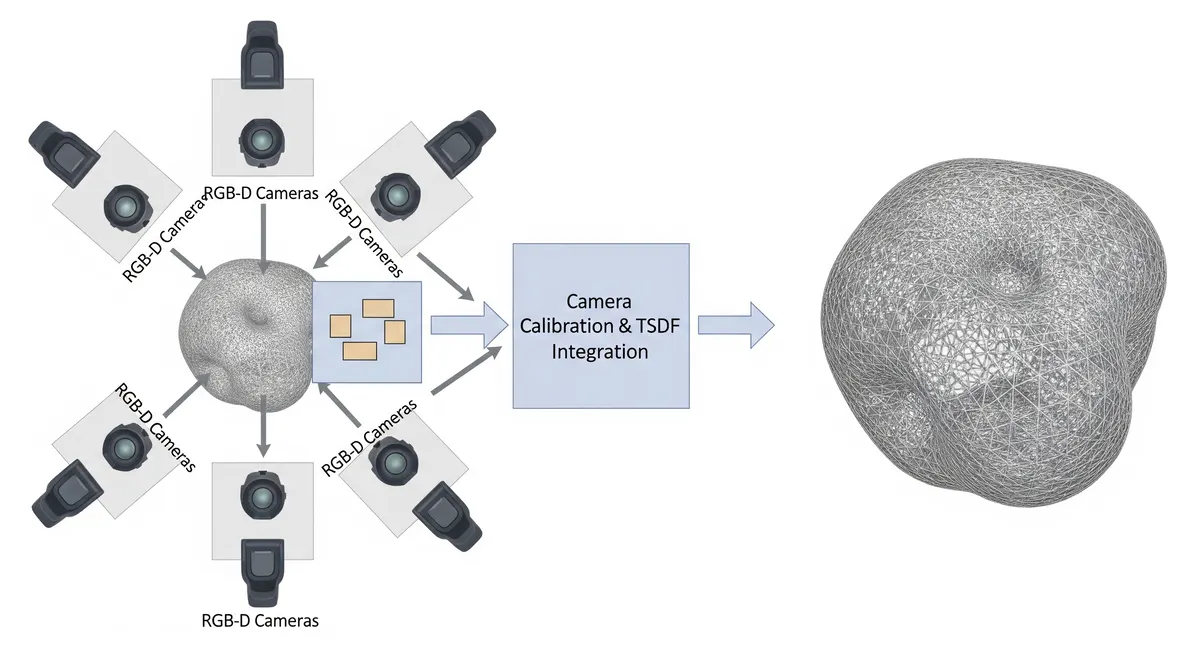
Volumetric capture with 8 RGB-D cameras
Multi-camera TSAI calibration and TSDF fusion into meshes for AR/VR, an early precursor to VoxaVerse.
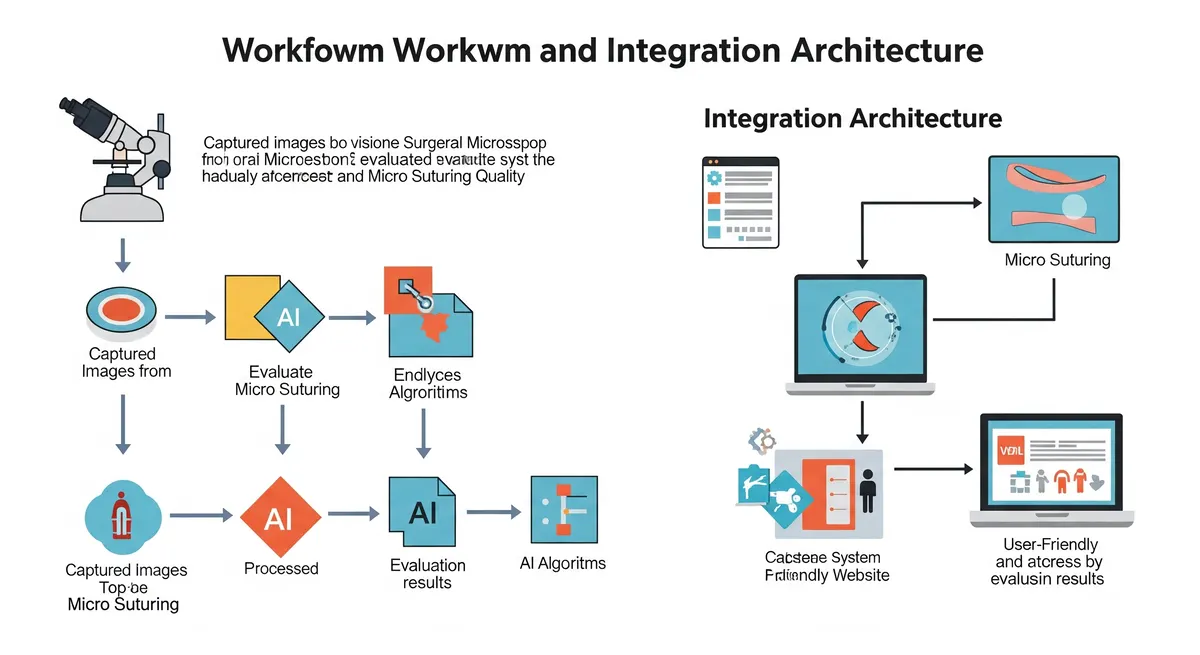
Micro-suturing assessment
Computer-vision scoring of micro-suturing for neurosurgical training, done with IIT Delhi and AIIMS Delhi.
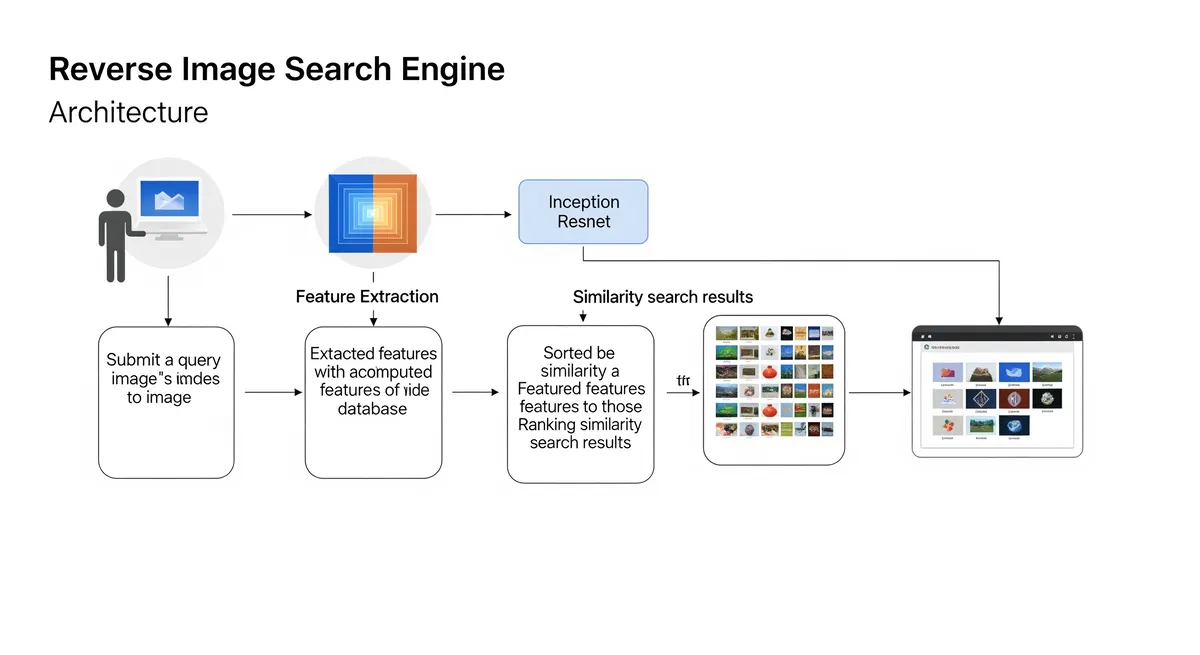
Reverse image search on heritage data
Inception-ResNet retrieval on the Indian Digital Heritage dataset.
More coursework: adversarial attacks (FGSM) on VGG16 (report) and a CloudSim hospital-management simulation (report).